我所侯涛刚老师课题组完成的论文《Cavity-Membrane-Based Water-Jet Bio-Inspired Thruster With Multidirectional Accelerating Capability》于2023-12在《IEEE/ASME Transactions on Mechatronics》正式发表。论文摘要如下:
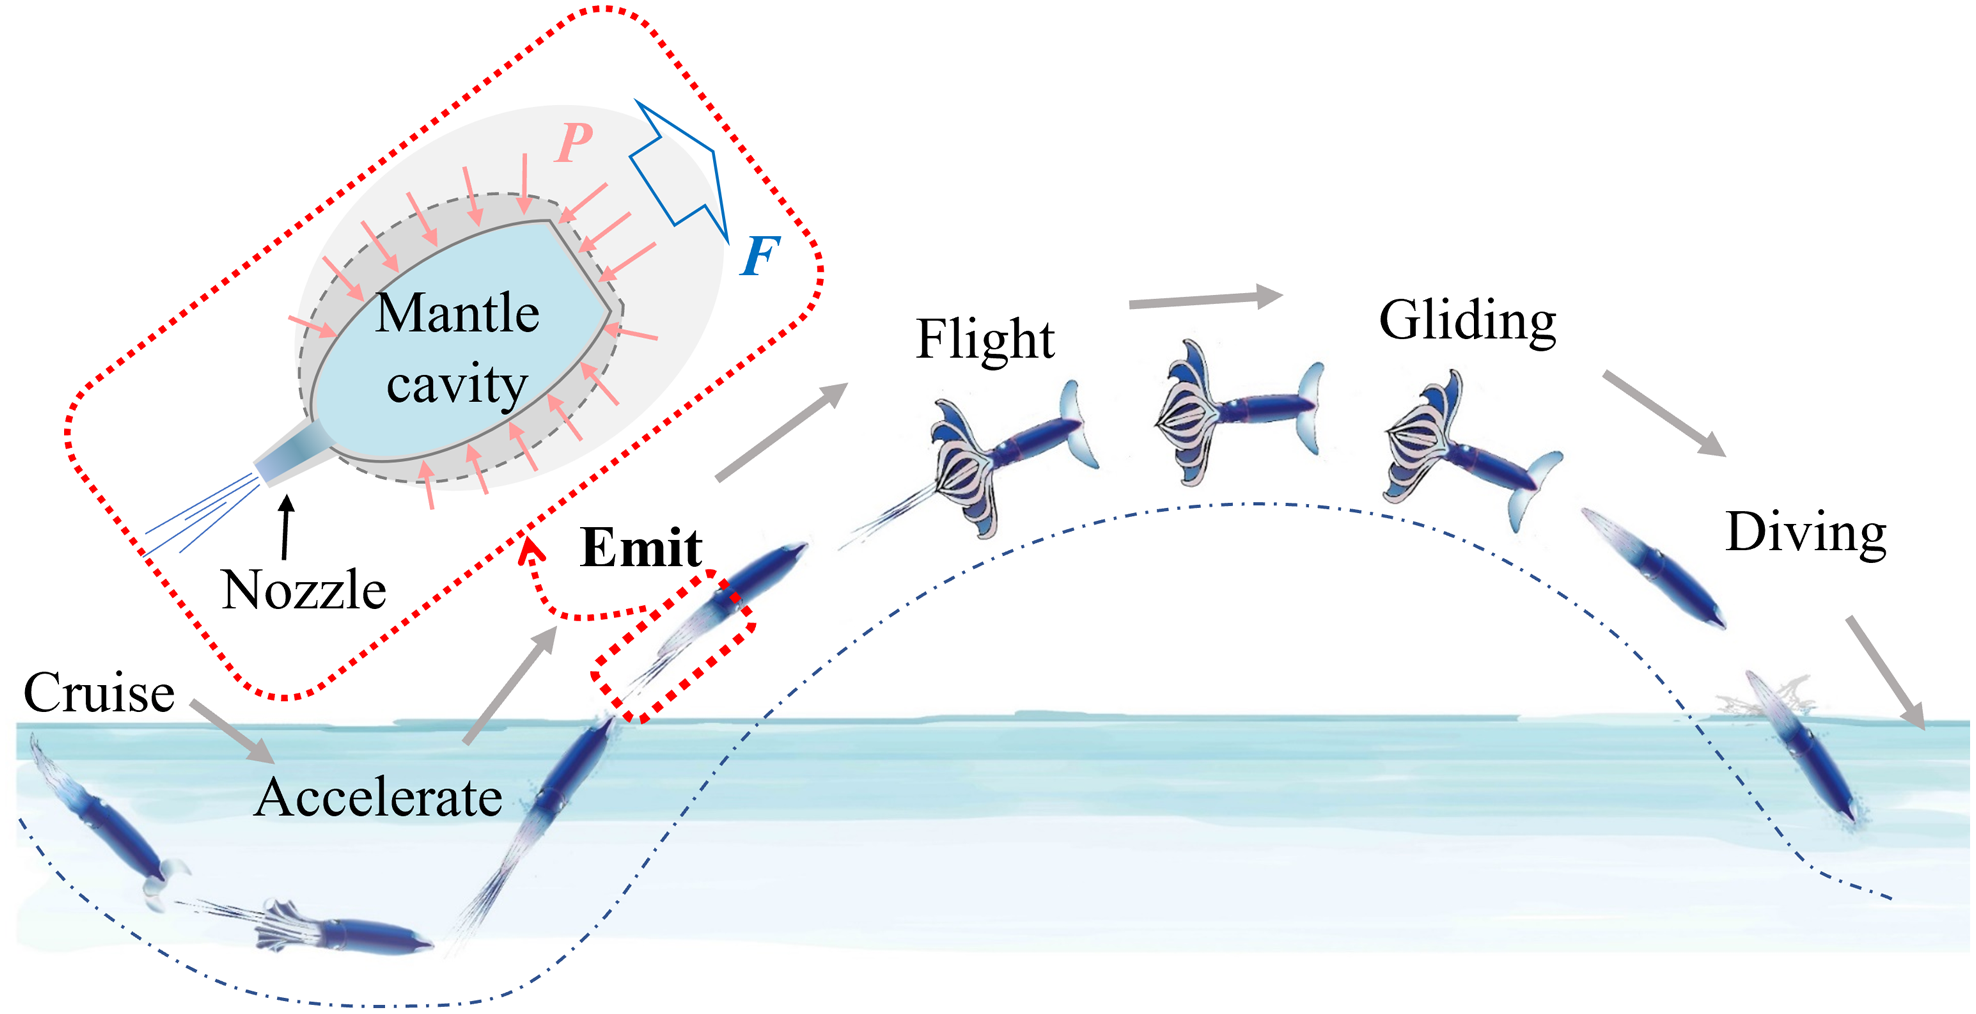
Abstract: Water-jet propulsion helps aquatic creatures achieve both accelerated motion (e.g., flying squid) and long-endurance cruising motion (e.g., jellyfish). That inspired the development of the aquatic unmanned aerial vehicle (AquaUAV) and underwater soft robots. Underwater soft robots achieve water-jet propulsion in all directions but have little propulsion thrust, AquaUAV has large propulsion thrust but can only accelerate from underwater to air. Here, to improve their deficiencies, we proposed a novel water-jet thrusters using cavity-membrane-based water-jet (CM-jet) structure. To quantitatively test the propulsion performance of this novel structure, a tethered prototype as well as a force-pressure measurement system was built. Propulsion theoretical models were developed and refined to explain the propulsion process of CM-jet structure. To explore and verify the propulsion rules, the launch angles α(0°, 15°, 30°, 45°, and 60°) and the initial pressure (0–0.3 MPa) of thruster were varied in the experiments. By combining simulation and experimental results, the thruster using CM-jet structure exhibited propulsion stability independent of launch angles. The maximum net peak thrust is 130 N when α = 30° and P = 0.3 MPa. With stable propulsion at any directions, the CM-jet structure may broaden the accelerating directions of water-jet, realizing three translational DoF, which provides a faster propulsion pattern apart from propeller for underwater robot and AquaUAV.
引用信息:Xinyang Wang, Xuan Pei, Ruixiang Zhu, Taogang Hou, Xingbang Yang. Cavity-Membrane-Based Water-Jet Bio-Inspired Thruster With Multidirectional Accelerating Capability. IEEE/ASME Transactions on Mechatronics, 2023-12-28. DOI: 10.1109/tmech.2023.3340885